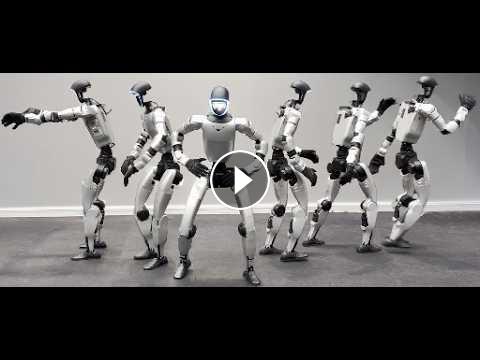
We present a real-time framework for expressive legged locomotion that enables independent control over velocity and style. Unlike existing data-driven controllers, which typically require explicit style labels for training, our method efficiently leverages large-scale unstructured motion data and generalizes to unseen styles. We disentangle style from functional locomotion through a tailored sampling strategy used to train a style encoder whose output conditions an autoregressive diffusion model. During inference, the user provides a style reference clip and a joystick velocity command. The diffusion model then generates a kinematic reference tracked by a reinforcement learning controller. To improve user controllability and stylization strength, we propose an attention biasing mechanism and a velocity command correction strategy. We demonstrate our method on a physics-based humanoid character in simulation and on a physical robot, showcasing robust real-time control and continuous style modulation.
Publication link: https://la.disneyresearch.com/publication/walk-like-this-stylized-locomotion-for-physics-based-characters-through-example-driven-diffusion
- Category
- CG VFX & Misc
Up Next
-
03:29

Unreal Engine 5 - Viking village of Njordheim (Based on Birka. Sweden)
-
00:27
Cyberpunk A stylized character
-
00:24
Muscle-driven creature | in-house test
-
00:31
Semi-Supervised Video-Driven Facial Animation Transfer
-
01:23
STYLIZED ENVIRONMENTS
-
02:25
DIFFUSION
-
00:38
Gulf x Williams Racing | Driven By Words
-
Kamino: GPU-based Simulation of Rigid Multi-Body Physics with Kinematic Loops
-
01:47
2grey R&D : Physics
-
43:54
The Mitchells vs. The Machines | Breaking Our Physically Based Renderer
-
07:57
Scavengers